全系列智能机器人产品
自研产品 + 代理锐曼全系列,覆盖多场景应用
热销产品
广泛应用于工业、商业、医疗等多个领域

lronBov Pro Transport Robot
铁牛Pro搬运机器人,内置锐曼机器人自主研发的导航定位算法,激光SLAM导航,无需贴码,600KG超大承重能力,10cm顶升高度,自动搬运货架,采用50m、40m双激光雷达和3D摄像头,全方位感知周围环境,运行稳定更安全,同时向所有用户开放SDK平台,提供全套的开发文档,支持二次开发,实现机器人应用落地。

Dual Laser FLY BOAT ROBOT CHASSIS
双激光飞船机器人底盘作为一款单向背负式搬运机器人,采用双激光雷达+3D摄像头融合技术,300KG超大载重能力,搭载锐曼自研SLAM 2.0自主定位导航系统,无需贴码,高精准导航定位,开放SDK平台,提供丰富的API接口,支持二次开发或定制化服务,满足不同机器人开发需求。

Hussar Pro Robot Chassis
轻骑兵 Pro-机器人底盘,100KG超大载重能力,搭载锐曼自研SLAM 2.0自主定位导航系统,轻松应对工厂各种狭窄过道,转弯半径更小,无需贴码,高精准导航定位,开放SDK平台,提供丰富的API接口,支持二次开发或定制化服务,满足不同机器人开发需求。

Robot navigation chassis
机器人导航底盘 拥有视觉定位、室内导航、智能避障等多种功能,主要由激光雷达传感器、深度摄像头、防跌落传感器,模块化定位导航系统等核心硬件组成。激光SLAM与V-SLAM多传感器融合算法,能更灵活的规划机器人行走路线。
About Zetis Technology
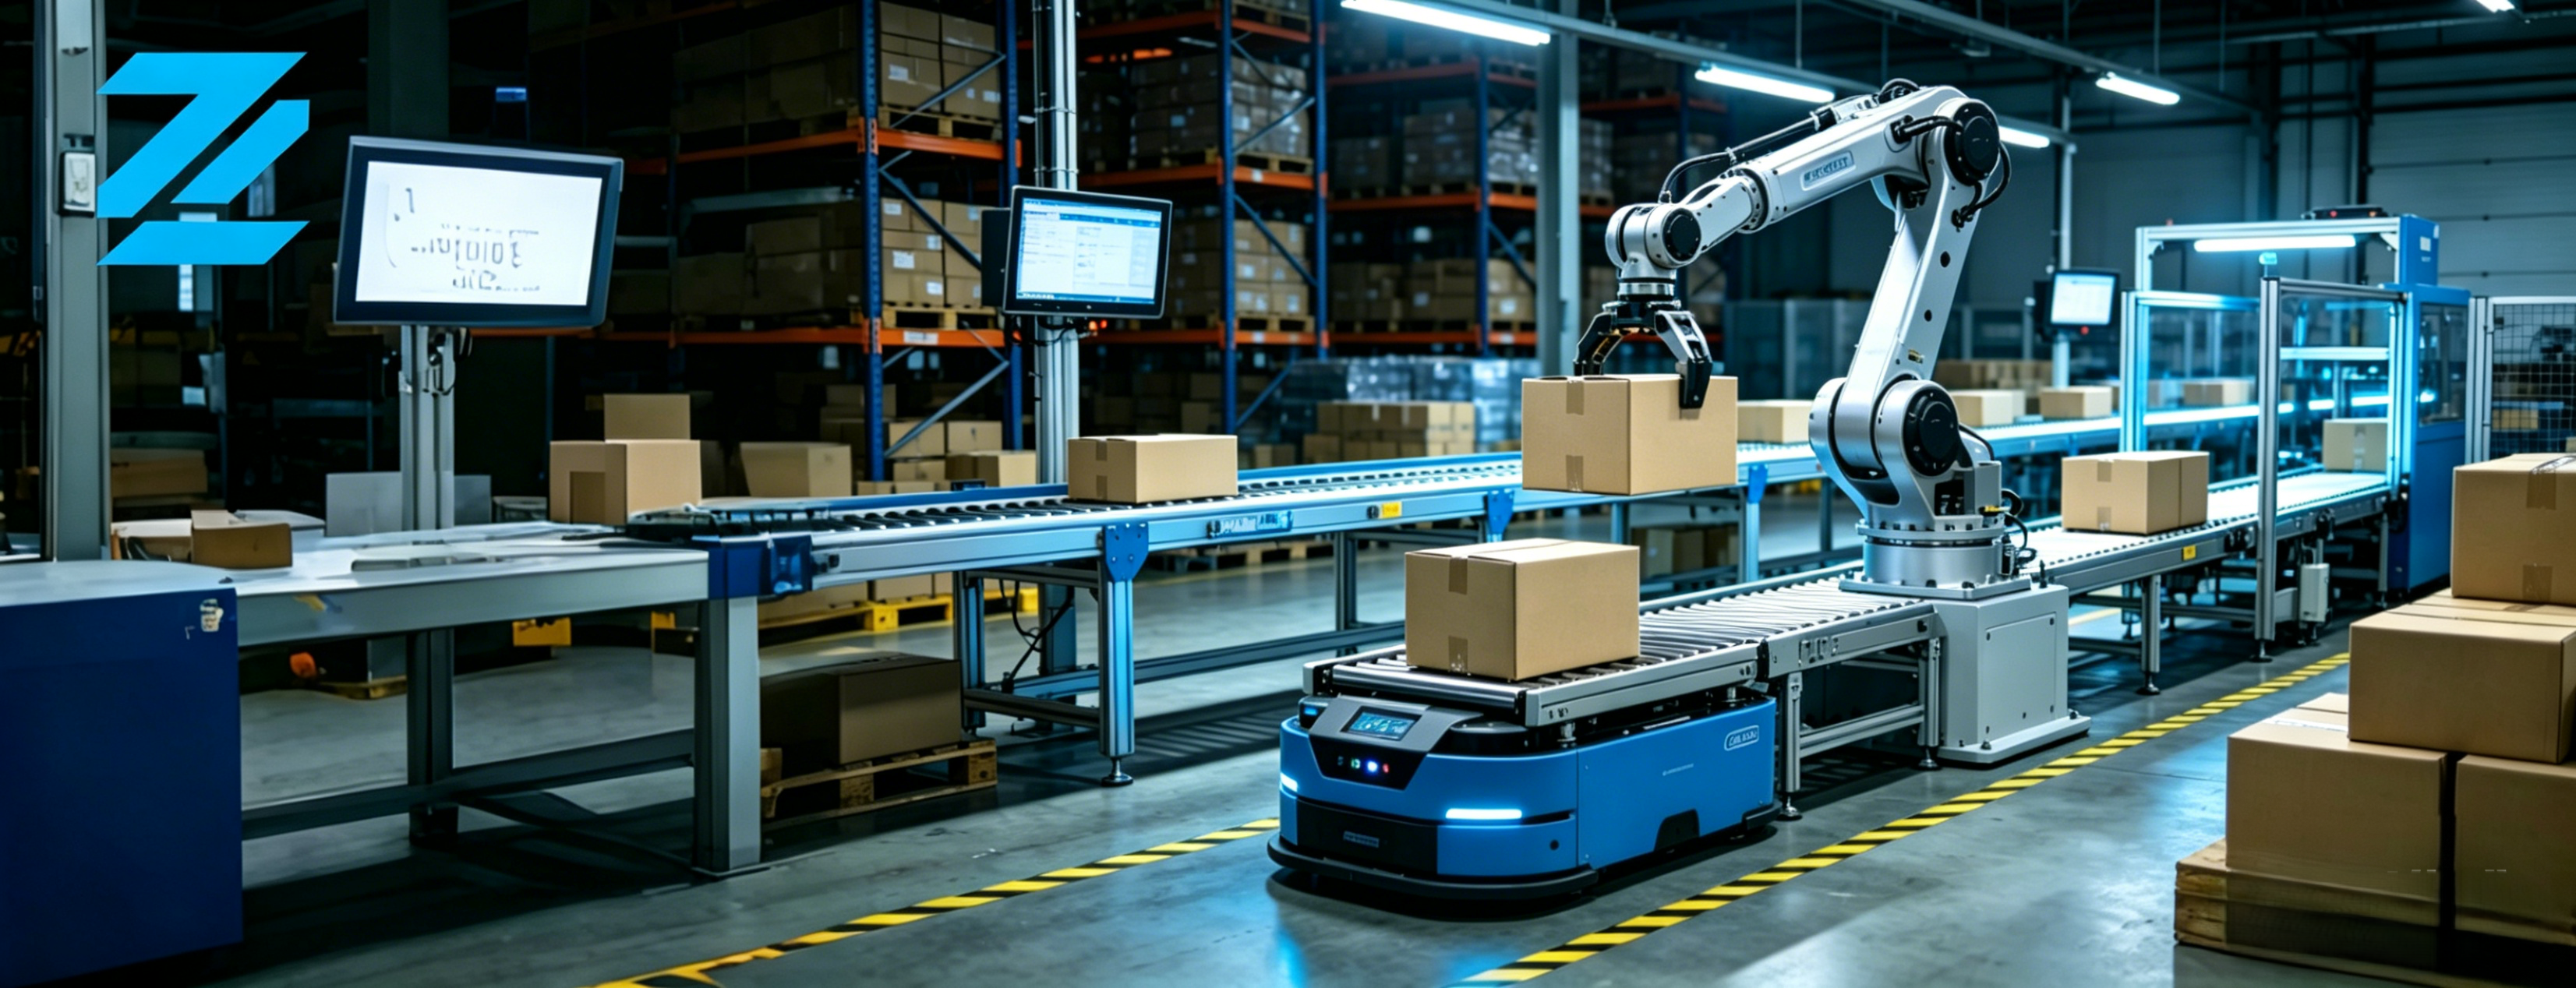
Pinghu Zetis Technology Co., Ltd. (Zetis) was established in 2023, and is a technology pioneer and trailblazer in the field of intelligent mobile robots in China, dedicated to providing advanced intelligent robot solutions to global customers. Since its establishment, we have been committed to the research and application of artificial intelligence, with fully independent intellectual property rights. We are the authorized agent of Reeman Intelligent’s full series of robot products, including autonomous forklifts, factory handling, cleaning, delivery and chassis, sold to more than 55 countries and regions worldwide.
最新动态
Zetis New Website is Live
Manage products and content easily with our new CMS.
Zetis Technology and Reeman Intelligent Reach Strategic Cooperation
Zetis Technology has formally reached a strategic cooperation with Reeman Intelligent, becoming an authorized agent for Reeman Intelligent’s robot series products, providing customers with comprehensive intelligent robot solutions.
Analysis of the Development Prospects of the Intelligent Robot Industry
With the continuous development of artificial intelligence technology, the intelligent robot industry has ushered in unprecedented development opportunities, with the market scale continuing to expand and application fields continuing to broaden.